2026

A minimally invasive robotic surgical system for anterior lumbar nerve decompression
Qingxiang Zhao*, Xiandi Wang*, Xin Zhong, Runfeng Zhu, Peizhi Zhou, Dan Pu, Baitao Lin, Tao Li, Shiyuan Sui, Haonan Zhou, Yuxi Cheng, Hao Zheng, Henry K. Chu, Jiancheng Zeng#, Kang Li# (* equal contribution)
Science Robotics 2026 Accepted
We present a minimally invasive anterior lumbar nerve decompression system built from three slender, high-dexterity concentric push-pull robotic (CPPR) arms. The system integrates an endoscope, laser optical fiber and gripper (each mounted on a 2-mm slender arm) with an 8-mm trocar, and was validated with vertebral phantom, animal, and human cadaver experiments.
A minimally invasive robotic surgical system for anterior lumbar nerve decompression
Qingxiang Zhao*, Xiandi Wang*, Xin Zhong, Runfeng Zhu, Peizhi Zhou, Dan Pu, Baitao Lin, Tao Li, Shiyuan Sui, Haonan Zhou, Yuxi Cheng, Hao Zheng, Henry K. Chu, Jiancheng Zeng#, Kang Li# (* equal contribution)
Science Robotics 2026 Accepted
We present a minimally invasive anterior lumbar nerve decompression system built from three slender, high-dexterity concentric push-pull robotic (CPPR) arms. The system integrates an endoscope, laser optical fiber and gripper (each mounted on a 2-mm slender arm) with an 8-mm trocar, and was validated with vertebral phantom, animal, and human cadaver experiments.
Multifunction Robotized Surgical Dissector for Endoscopic Pulmonary Thromboendarterectomy: Preclinical Study and Evaluation
Runfeng Zhu, Xin Zhong, Qingxiang Zhao, Jing Lin, Zhong Wu, Kang Li#
Soft Robotics 2026 Accepted
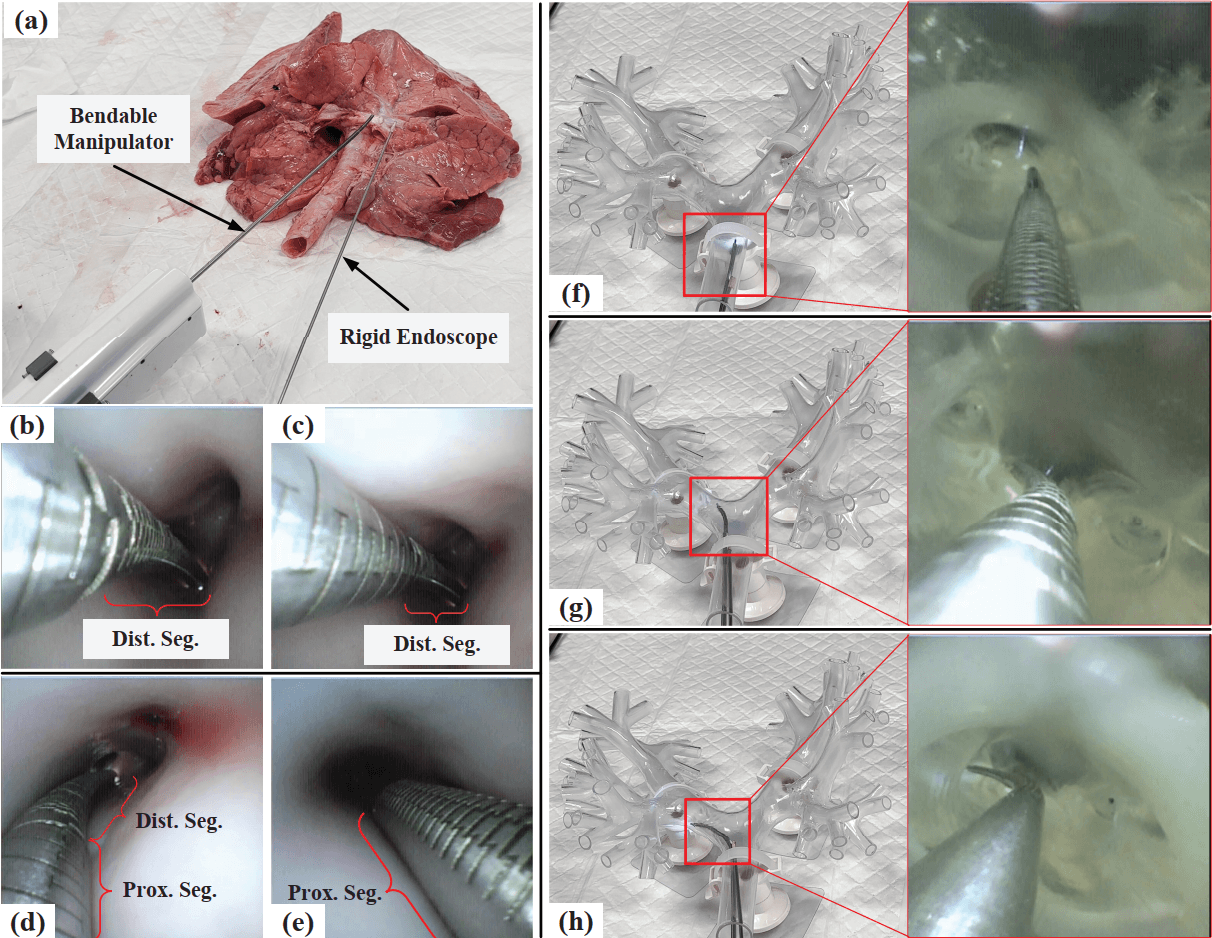
We present a slender, dual-segment-bending robotized dissector based on a concentric push/pull robot for endoscopic pulmonary thromboendarterectomy. Its stiffness, motion accuracy, maneuverability, and ex vivo porcine-lung performance were evaluated for minimally invasive surgery.
Multifunction Robotized Surgical Dissector for Endoscopic Pulmonary Thromboendarterectomy: Preclinical Study and Evaluation
Runfeng Zhu, Xin Zhong, Qingxiang Zhao, Jing Lin, Zhong Wu, Kang Li#
Soft Robotics 2026 Accepted
We present a slender, dual-segment-bending robotized dissector based on a concentric push/pull robot for endoscopic pulmonary thromboendarterectomy. Its stiffness, motion accuracy, maneuverability, and ex vivo porcine-lung performance were evaluated for minimally invasive surgery.
2025
A Handheld, Dual-Arm Surgical Device for Semi-Automated Trans-oral Endoscopic Resection
Xin Zhong, Runfeng Zhu, Qingxiang Zhao, Yong Zhong, Kang Li#
IEEE 21st International Conference on Automation Science and Engineering (CASE) 2025 Accepted
We present a portable handheld dual-arm system for transoral surgery, combining a tendon-driven continuum master arm for tissue manipulation with a slender concentric push-pull endoscopic slave arm for scene monitoring. Miniaturized actuators and automatic eye-hand coordination address the dexterity limitations of conventional transoral tools, with experiments demonstrating clinical potential in endoscopic tonsillectomy.
A Handheld, Dual-Arm Surgical Device for Semi-Automated Trans-oral Endoscopic Resection
Xin Zhong, Runfeng Zhu, Qingxiang Zhao, Yong Zhong, Kang Li#
IEEE 21st International Conference on Automation Science and Engineering (CASE) 2025 Accepted
We present a portable handheld dual-arm system for transoral surgery, combining a tendon-driven continuum master arm for tissue manipulation with a slender concentric push-pull endoscopic slave arm for scene monitoring. Miniaturized actuators and automatic eye-hand coordination address the dexterity limitations of conventional transoral tools, with experiments demonstrating clinical potential in endoscopic tonsillectomy.
2024

Ultra-slender Coaxial Antagonistic Tubular Robot for Ambidextrous Manipulation
Qingxiang Zhao, Runfeng Zhu, Xin Zhong, Baitao Lin, Xiandi Wang, Xilong Hou, Jian Hu, Kang Li#
arXiv preprint arXiv:2412.18879 2024 Preprint
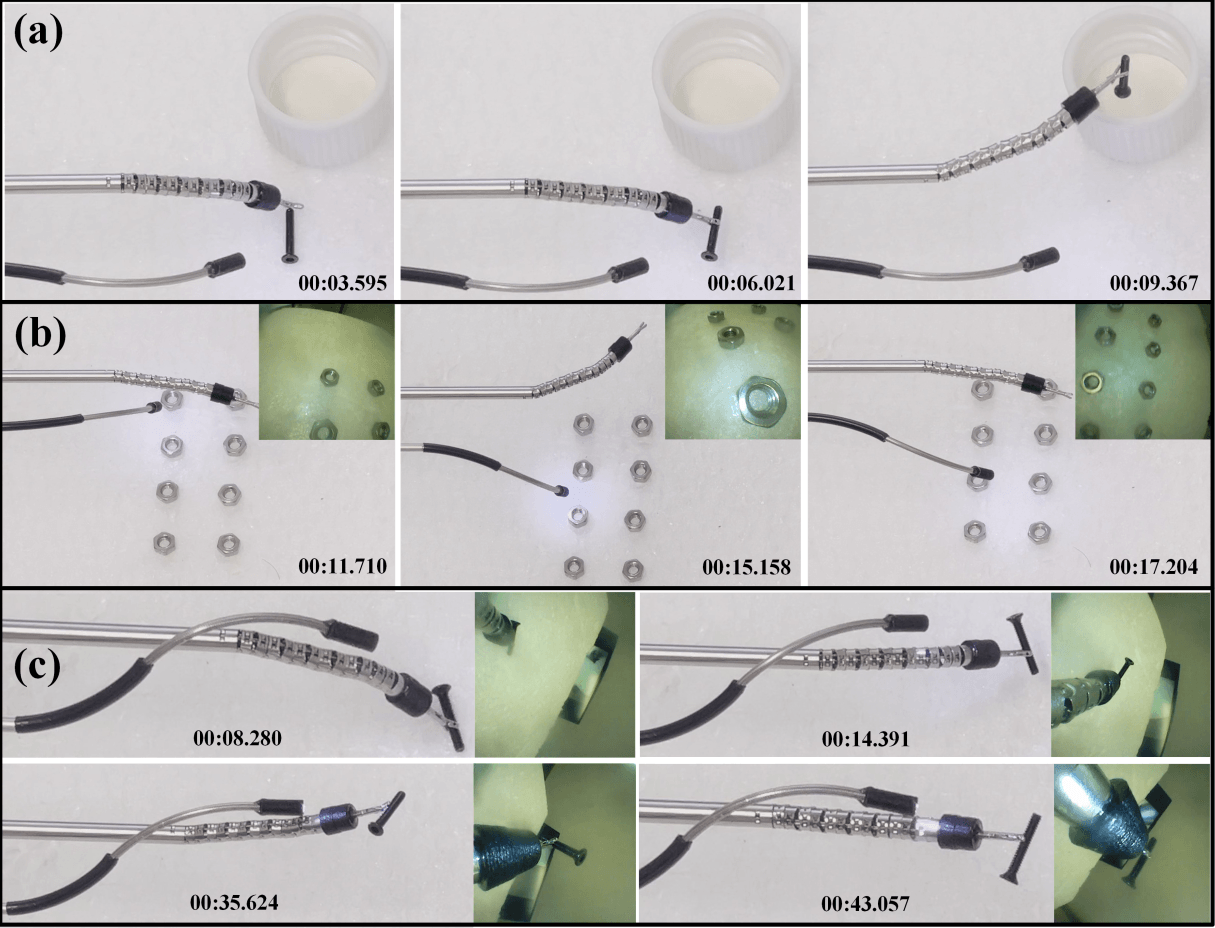
We propose an asymmetric coaxial antagonistic tubular robot with high stiffness and dexterity for manipulation in narrow spaces. The work develops its kinematic and statics models, slit design, optimization-based control, and experimental validation for minimally invasive applications.
Ultra-slender Coaxial Antagonistic Tubular Robot for Ambidextrous Manipulation
Qingxiang Zhao, Runfeng Zhu, Xin Zhong, Baitao Lin, Xiandi Wang, Xilong Hou, Jian Hu, Kang Li#
arXiv preprint arXiv:2412.18879 2024 Preprint
We propose an asymmetric coaxial antagonistic tubular robot with high stiffness and dexterity for manipulation in narrow spaces. The work develops its kinematic and statics models, slit design, optimization-based control, and experimental validation for minimally invasive applications.