Xin Zhong Eric
M.S Student
Logo Shanghai Jiao Tong University
About Me

I am Xin Zhong, a first-year M.S. student at the School of Mechanical Engineering, Shanghai Jiao Tong University (SJTU). Before that, I received my B.S. degree in Mechanical Engineering from University of Electronic Science and Technology of China (UESTC) in 2026.

Interests

My research interests focus on Robotics and Embodied Intelligence. With rich experience in mechanical design, embedded electronics and robotic system integration, I work across the complete robotics pipeline from theoretical modeling and algorithm development to hardware implementation and real-world validation. I'm also an active contributor to many open-source projects.
I am currently building my foundations in reinforcement learning (with lectures given by Prof. Shiyu Zhao, and CS285 from UC Berkeley), with a particular interest in its applications to robotics.

Curriculum Vitae

Education
  • Shanghai Jiao Tong University
    Shanghai Jiao Tong University
    School of Mechanical Engineering
    M.S. Student
    Sep. 2026 - present
  • University of Electronic Science and Technology of China
    University of Electronic Science and Technology of China
    Mechanical Design, Manufacturing and Automation
    B.S. in Mechanical Engineering
    Sep. 2022 - Jun. 2026
Experience
  • West China Hospital, Sichuan University
    West China Hospital, Sichuan University
    Algorithm & Control Leader of MicroSpine Surgical Robot
    Research Assistant
    May. 2024 - Nov. 2025
  • HKUST SZ-HK Collaborative Innovation Research Institute
    HKUST SZ-HK Collaborative Innovation Research Institute
    Develop Robotic Fiber Winding Machine
    Research Assistant
    Aug. 2025 - Sep. 2025
Honors & Awards
  • Outstanding Undergraduate Thesis of UESTC (Top 1%)
    2026
  • National First Prize, 2025 National Undergraduate Electronic Design Contest
    2025
  • National First Prize, 17th National Undergraduate Advanced Drawing Technology Modeling Competition
    2024
  • National Scholarship
    2024
  • Outstanding Undergraduate Scholarship of UESTC
    2023 - 2025
Selected Publications (view all )
A minimally invasive robotic surgical system for anterior lumbar nerve decompression

Qingxiang Zhao*, Xiandi Wang*, Xin Zhong, Runfeng Zhu, Peizhi Zhou, Dan Pu, Baitao Lin, Tao Li, Shiyuan Sui, Haonan Zhou, Yuxi Cheng, Hao Zheng, Henry K. Chu, Jiancheng Zeng#, Kang Li# (* equal contribution)

Science Robotics 2026 Accepted

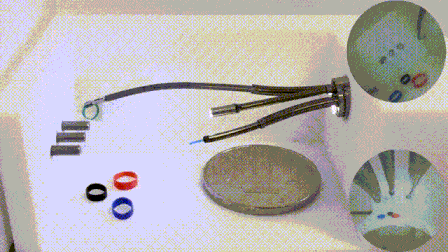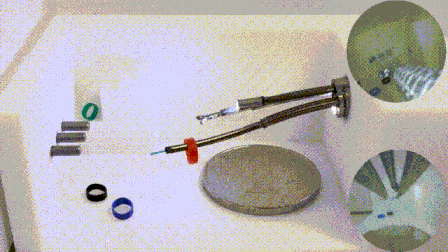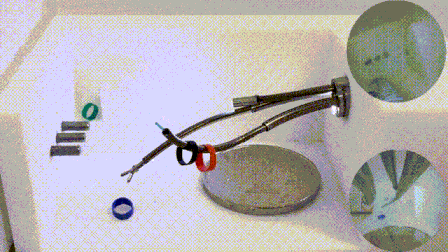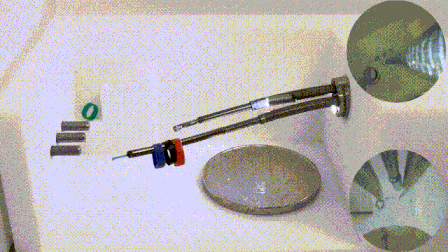
We present a minimally invasive anterior lumbar nerve decompression system built from three slender, high-dexterity concentric push-pull robotic (CPPR) arms. The system integrates an endoscope, laser optical fiber and gripper (each mounted on a 2-mm slender arm) with an 8-mm trocar, and was validated with vertebral phantom, animal, and human cadaver experiments.

A minimally invasive robotic surgical system for anterior lumbar nerve decompression

Qingxiang Zhao*, Xiandi Wang*, Xin Zhong, Runfeng Zhu, Peizhi Zhou, Dan Pu, Baitao Lin, Tao Li, Shiyuan Sui, Haonan Zhou, Yuxi Cheng, Hao Zheng, Henry K. Chu, Jiancheng Zeng#, Kang Li# (* equal contribution)

Science Robotics 2026 Accepted

We present a minimally invasive anterior lumbar nerve decompression system built from three slender, high-dexterity concentric push-pull robotic (CPPR) arms. The system integrates an endoscope, laser optical fiber and gripper (each mounted on a 2-mm slender arm) with an 8-mm trocar, and was validated with vertebral phantom, animal, and human cadaver experiments.

Multifunction Robotized Surgical Dissector for Endoscopic Pulmonary Thromboendarterectomy: Preclinical Study and Evaluation

Runfeng Zhu, Xin Zhong, Qingxiang Zhao, Jing Lin, Zhong Wu, Kang Li#

Soft Robotics 2026 Accepted

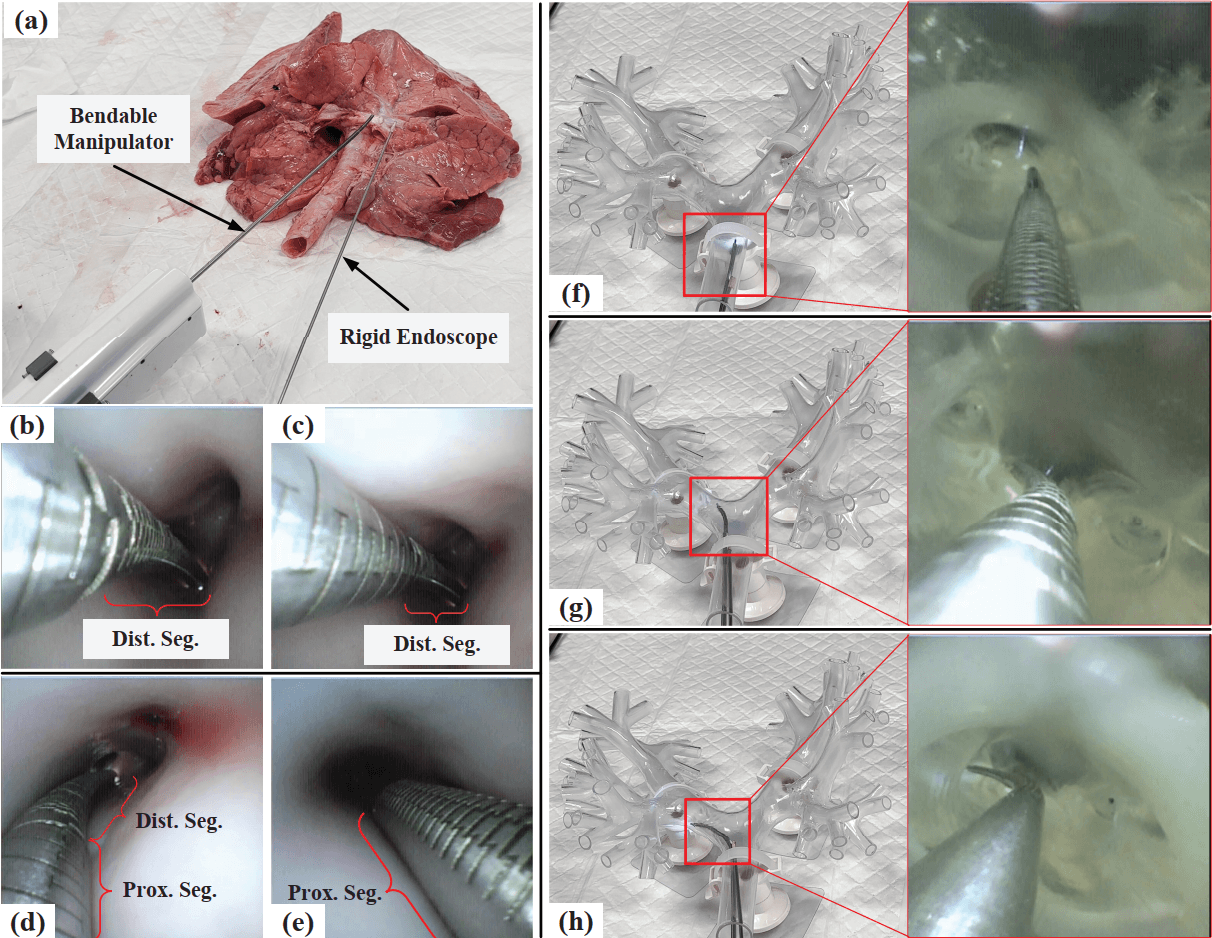
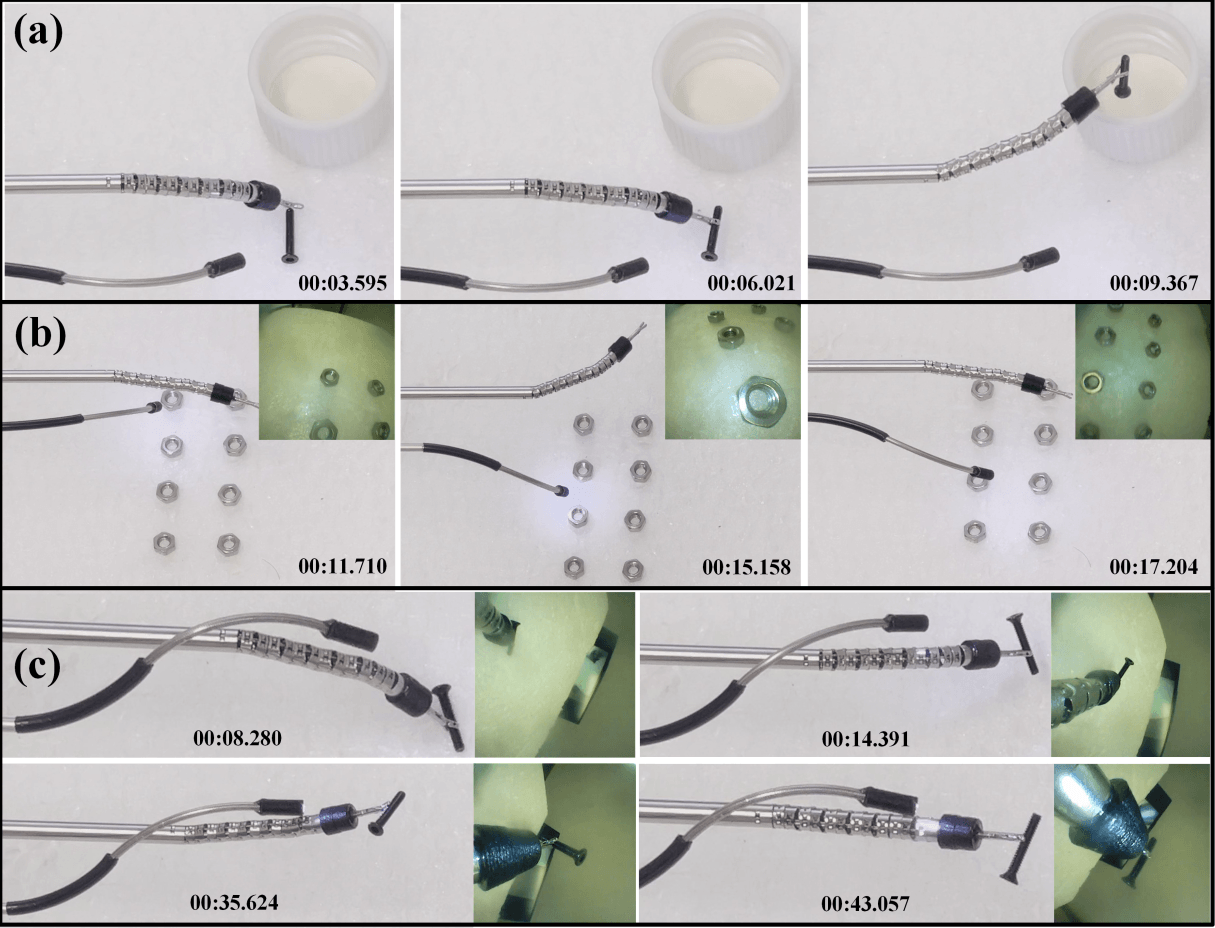
We present a slender, dual-segment-bending robotized dissector based on a concentric push/pull robot for endoscopic pulmonary thromboendarterectomy. Its stiffness, motion accuracy, maneuverability, and ex vivo porcine-lung performance were evaluated for minimally invasive surgery.

Multifunction Robotized Surgical Dissector for Endoscopic Pulmonary Thromboendarterectomy: Preclinical Study and Evaluation

Runfeng Zhu, Xin Zhong, Qingxiang Zhao, Jing Lin, Zhong Wu, Kang Li#

Soft Robotics 2026 Accepted

We present a slender, dual-segment-bending robotized dissector based on a concentric push/pull robot for endoscopic pulmonary thromboendarterectomy. Its stiffness, motion accuracy, maneuverability, and ex vivo porcine-lung performance were evaluated for minimally invasive surgery.

A Handheld, Dual-Arm Surgical Device for Semi-Automated Trans-oral Endoscopic Resection

Xin Zhong, Runfeng Zhu, Qingxiang Zhao, Yong Zhong, Kang Li#

IEEE 21st International Conference on Automation Science and Engineering (CASE) 2025 Accepted

We present a portable handheld dual-arm system for transoral surgery, combining a tendon-driven continuum master arm for tissue manipulation with a slender concentric push-pull endoscopic slave arm for scene monitoring. Miniaturized actuators and automatic eye-hand coordination address the dexterity limitations of conventional transoral tools, with experiments demonstrating clinical potential in endoscopic tonsillectomy.

A Handheld, Dual-Arm Surgical Device for Semi-Automated Trans-oral Endoscopic Resection

Xin Zhong, Runfeng Zhu, Qingxiang Zhao, Yong Zhong, Kang Li#

IEEE 21st International Conference on Automation Science and Engineering (CASE) 2025 Accepted

We present a portable handheld dual-arm system for transoral surgery, combining a tendon-driven continuum master arm for tissue manipulation with a slender concentric push-pull endoscopic slave arm for scene monitoring. Miniaturized actuators and automatic eye-hand coordination address the dexterity limitations of conventional transoral tools, with experiments demonstrating clinical potential in endoscopic tonsillectomy.

Ultra-slender Coaxial Antagonistic Tubular Robot for Ambidextrous Manipulation

Qingxiang Zhao, Runfeng Zhu, Xin Zhong, Baitao Lin, Xiandi Wang, Xilong Hou, Jian Hu, Kang Li#

arXiv preprint arXiv:2412.18879 2024 Preprint

We propose an asymmetric coaxial antagonistic tubular robot with high stiffness and dexterity for manipulation in narrow spaces. The work develops its kinematic and statics models, slit design, optimization-based control, and experimental validation for minimally invasive applications.

Ultra-slender Coaxial Antagonistic Tubular Robot for Ambidextrous Manipulation

Qingxiang Zhao, Runfeng Zhu, Xin Zhong, Baitao Lin, Xiandi Wang, Xilong Hou, Jian Hu, Kang Li#

arXiv preprint arXiv:2412.18879 2024 Preprint

We propose an asymmetric coaxial antagonistic tubular robot with high stiffness and dexterity for manipulation in narrow spaces. The work develops its kinematic and statics models, slit design, optimization-based control, and experimental validation for minimally invasive applications.

All publications
Projects
MicroSpine Single-Port Surgical Robot

2026

An 8-mm single-port surgical robot with three slender 2-mm robotic arms (endoscope, holmium laser and gripper arm) designed specifically for Oblique Lateral Interbody Fusion (OLIF) surgery. I independently designed the whole electronic system (EtherCAT, FOC, Host PC, ...) and control algorithm (IK, Eye-hand coordination, HMI, ...), and the resulting system was reported in Science Robotics.

[Paper] [Media Report]

6-DoF Robotic Arm with Visual Servo Control

2026

Designed and built a 6-DoF robotic arm integrating custom FOC joint drives, dual absolute encoders, a CAN-FD bus and ROS 2 control stack. Through proper sim-to-real modeling, precise force feedback and gravity compensation are realized. The experiments show that the system achieved a payload above 2.5 kg, no-load repeatability within ±0.012 mm, and visual tracking at over 30 Hz. This project was recognized as Outstanding Undergraduate Graduation Designs of UESTC.

[Thesis] [Repeatability Test] [Gravity Compensation Test]

Dual-Arm Master Manipulator with Force Feedback for Surgical Robots

2026

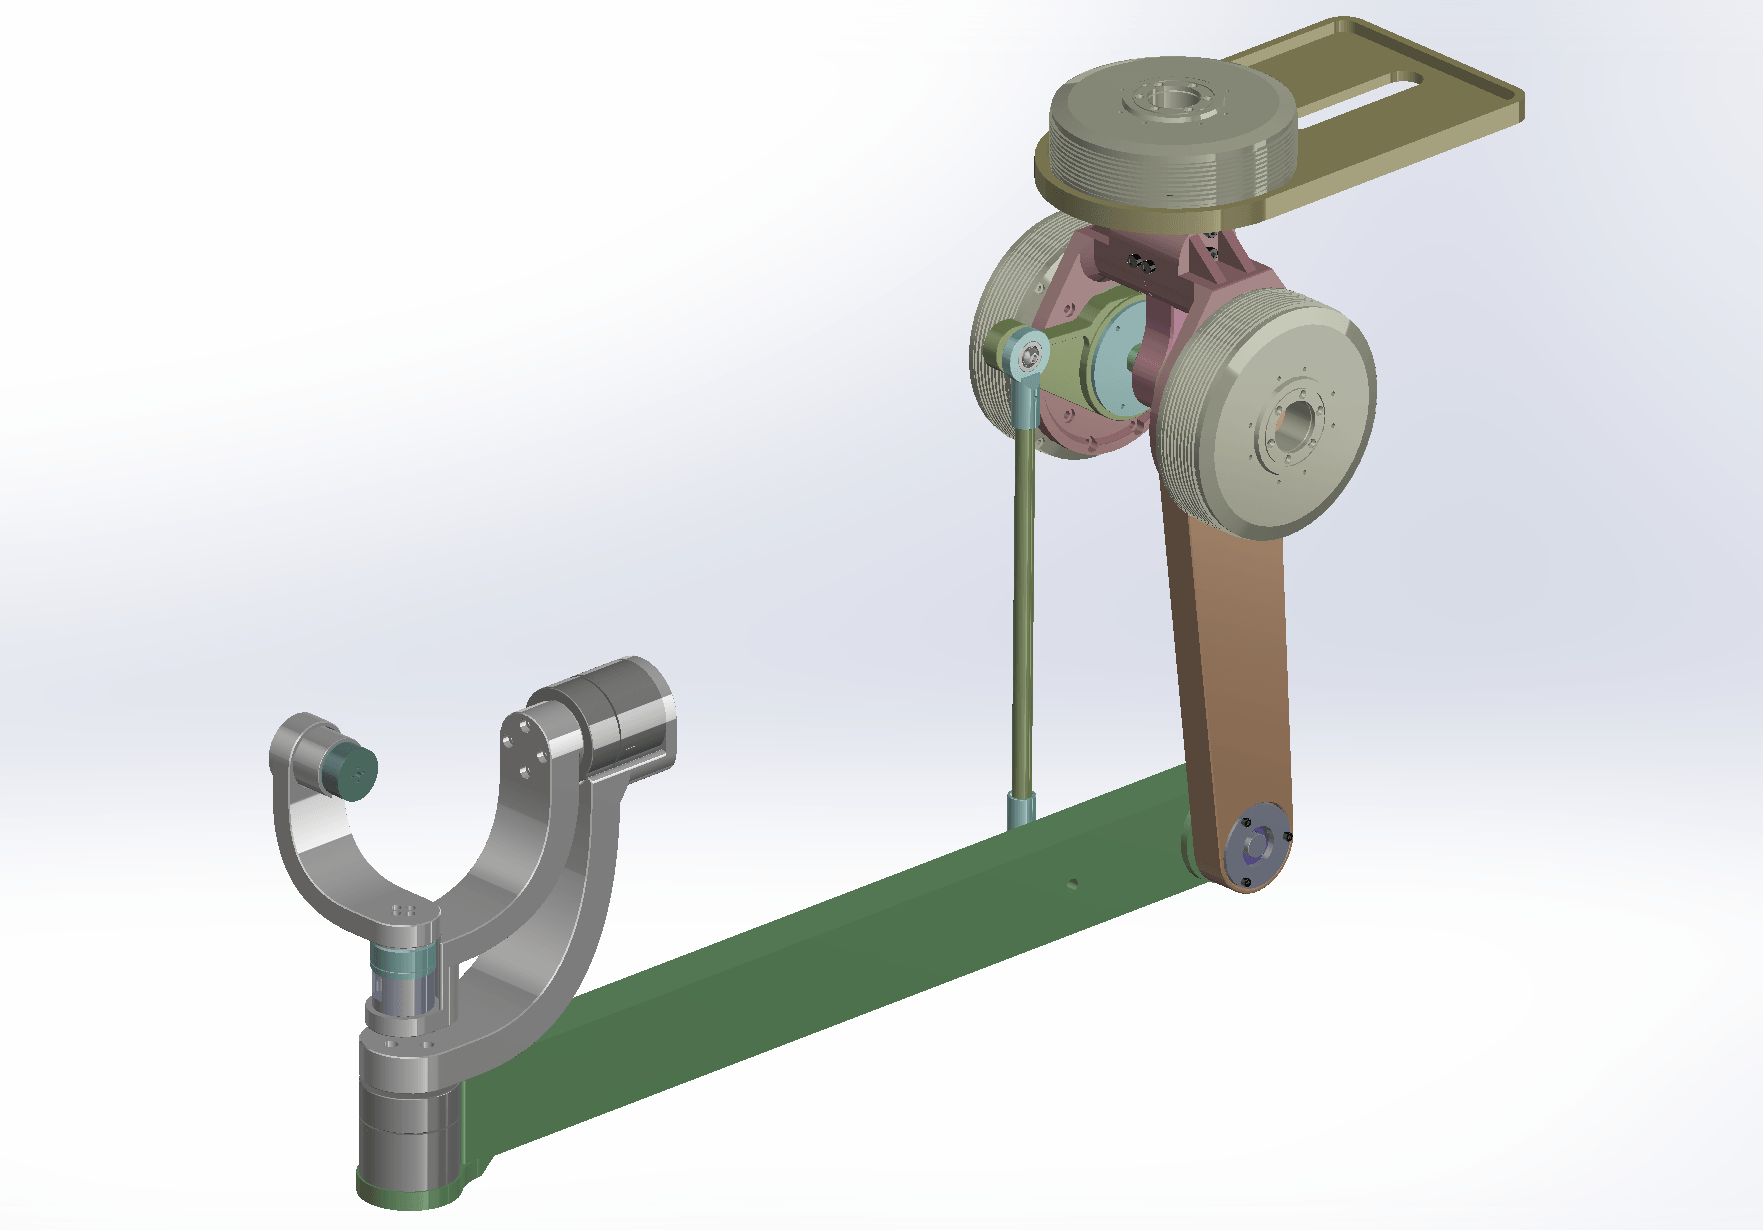
A dual-arm master manipulator for surgical robot teleoperation, designed to translate and smooth the operator's hand movements into robotic instrument commands, and provide force feedback from the end effector. The interaction concept and logic are inspired by the surgeon console of the da Vinci surgical system.

TouchUMI: A Force-Control Gripper with Tactile Sensing for Embodied Data Collection

2026

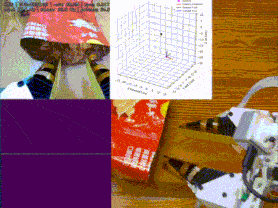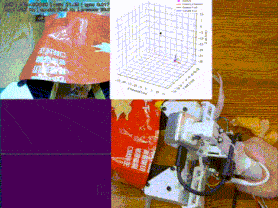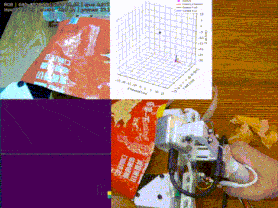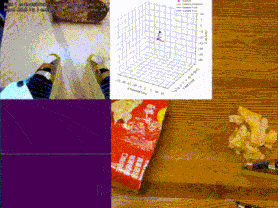
A gripper designed for Universal Manipulation Interface (UMI) style embodied data collection, suitable for both handheld operation and mounting on the robot arm. It extends the UMI concept with extra tactile sensing and current-based contact force control. An RGB-D stereo camera tracks the gripper pose through SLAM-based odometry, and the tactile sensing module is based on a modified FlexiTac Mini design with a smaller but higher-performance readout board, achieving a tactile streaming rate above 60 FPS.

FlexiTac Mini: Highly Integrated Resistive Tactile Sensor

2026

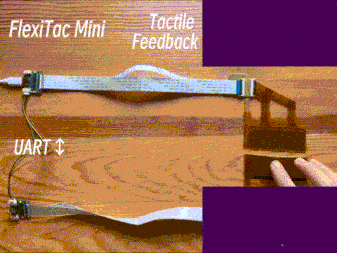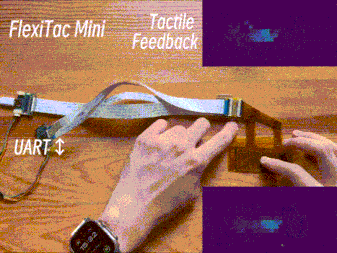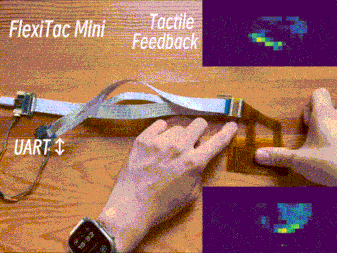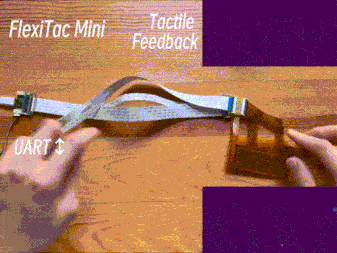
A miniature hardware design for FlexiTac tactile sensors with smaller footprint, stronger performance and many other improvements for large-scale deployment and synchronization. This project was validated through my next Touch-UMI gripper design.

[Code]

iFOC: Intelligent Field Oriented Control System for BLDC/PMSM Motors

2025

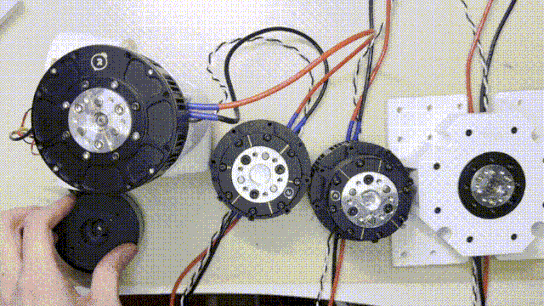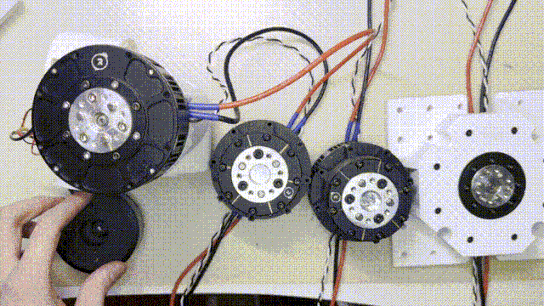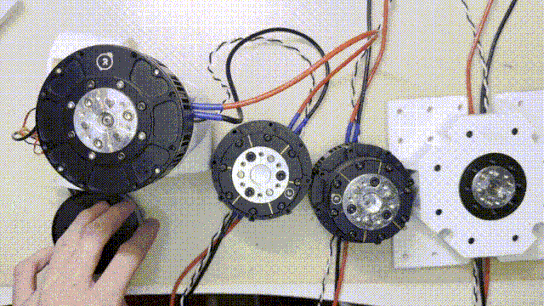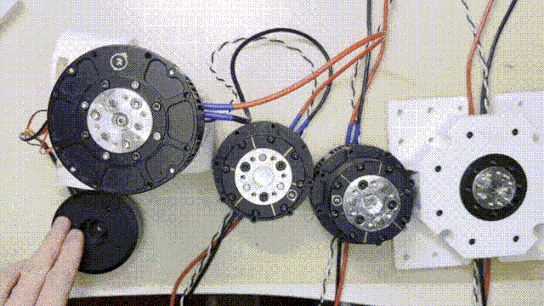
An open-source, high-performance field oriented control (FOC) framework for BLDC and PMSM motors. Built on a modular, abstract architecture, every core module is configurable at run-time, enabling iFOC to support multiple control modes and deployment across multiple platforms. This project serves as a fundamental platform for my follow-up works, including surgical robots, robot arms, etc.

[Code]

Maglev: Magnetic Levitation System

2024

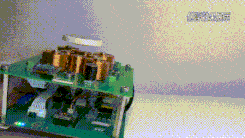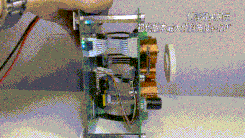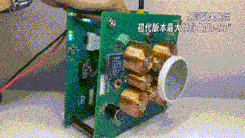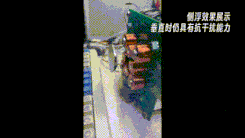
A magnetic levitation platform that combines cascaded current + position + 3D attitude PID loops to stabilize and control a levitated magnet disk. The system supports closed-loop height and orbital motion control, recovers from external disturbances, and maintains stable levitation with the base tilted by up to 135°-140°.

[Code] [Demo] [Report]