2026

MicroSpine Single-Port Surgical Robot

2026

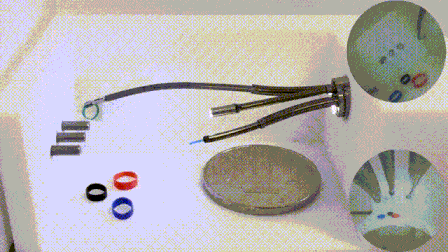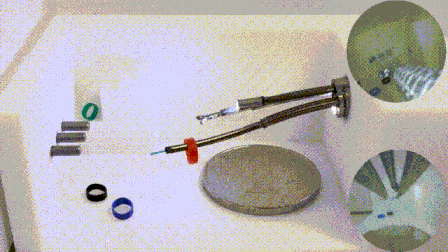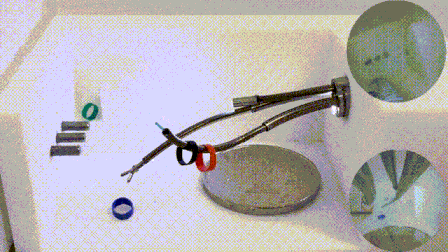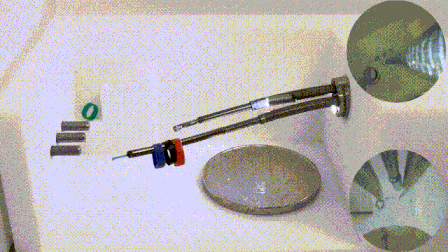
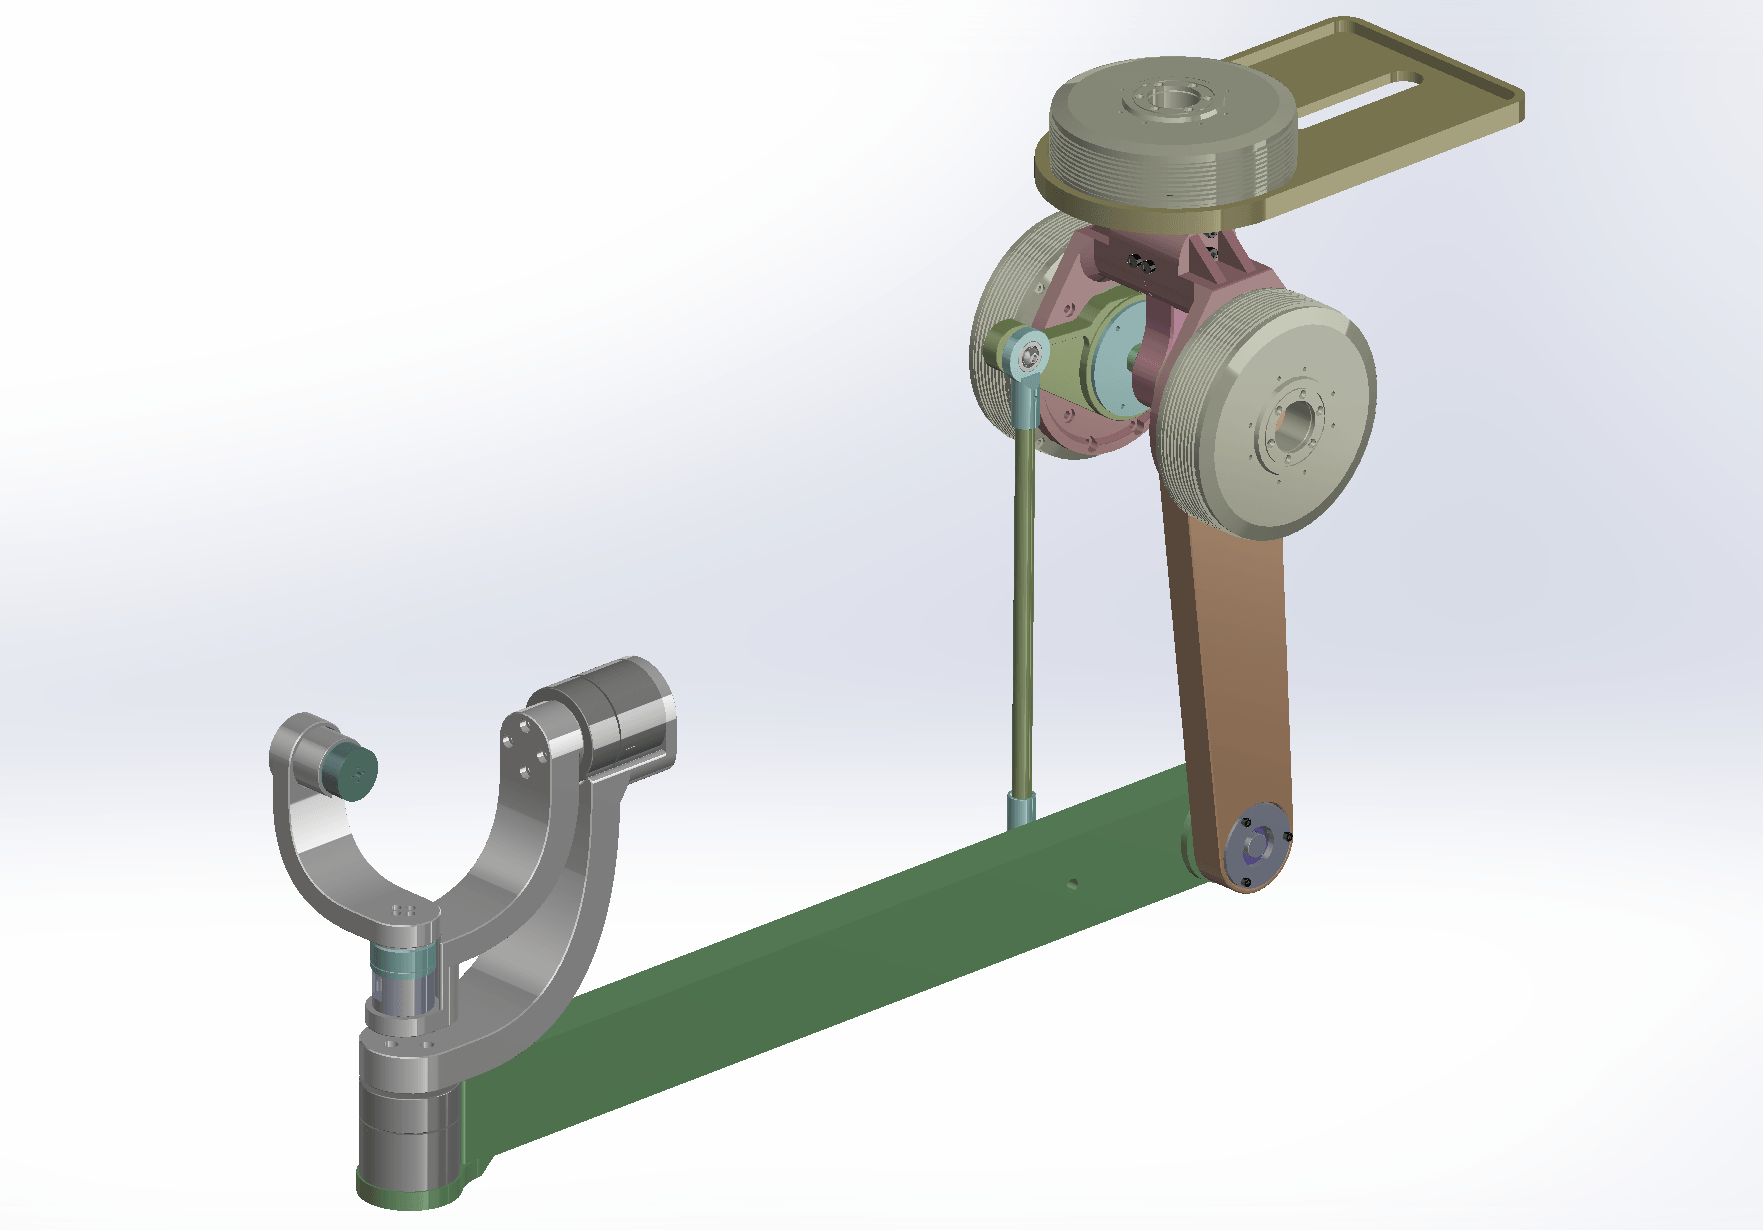
An 8-mm single-port surgical robot with three slender 2-mm robotic arms (endoscope, holmium laser and gripper arm) designed specifically for Oblique Lateral Interbody Fusion (OLIF) surgery. I independently designed the whole electronic system (EtherCAT, FOC, Host PC, ...) and control algorithm (IK, Eye-hand coordination, HMI, ...), and the resulting system was reported in Science Robotics.

[Paper] [Media Report]

6-DoF Robotic Arm with Visual Servo Control

2026

Designed and built a 6-DoF robotic arm integrating custom FOC joint drives, dual absolute encoders, a CAN-FD bus and ROS 2 control stack. Through proper sim-to-real modeling, precise force feedback and gravity compensation are realized. The experiments show that the system achieved a payload above 2.5 kg, no-load repeatability within ±0.012 mm, and visual tracking at over 30 Hz. This project was recognized as Outstanding Undergraduate Graduation Designs of UESTC.

[Thesis] [Repeatability Test] [Gravity Compensation Test]

Dual-Arm Master Manipulator with Force Feedback for Surgical Robots

2026

A dual-arm master manipulator for surgical robot teleoperation, designed to translate and smooth the operator's hand movements into robotic instrument commands, and provide force feedback from the end effector. The interaction concept and logic are inspired by the surgeon console of the da Vinci surgical system.

TouchUMI: A Force-Control Gripper with Tactile Sensing for Embodied Data Collection

2026

A gripper designed for Universal Manipulation Interface (UMI) style embodied data collection, suitable for both handheld operation and mounting on the robot arm. It extends the UMI concept with extra tactile sensing and current-based contact force control. An RGB-D stereo camera tracks the gripper pose through SLAM-based odometry, and the tactile sensing module is based on a modified FlexiTac Mini design with a smaller but higher-performance readout board, achieving a tactile streaming rate above 60 FPS.

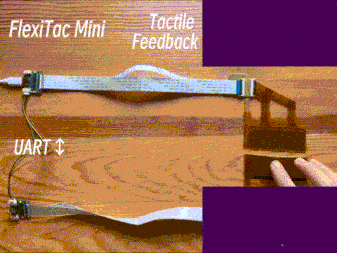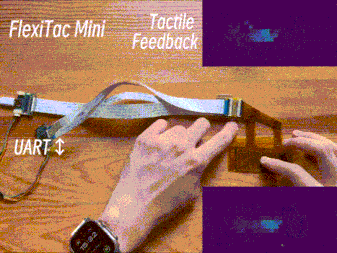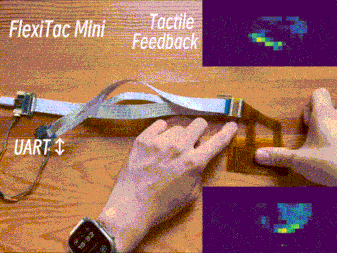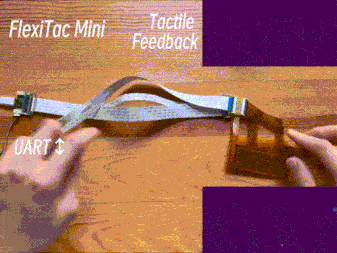
FlexiTac Mini: Highly Integrated Resistive Tactile Sensor

2026

A miniature hardware design for FlexiTac tactile sensors with smaller footprint, stronger performance and many other improvements for large-scale deployment and synchronization. This project was validated through my next Touch-UMI gripper design.

[Code]

2025

iFOC: Intelligent Field Oriented Control System for BLDC/PMSM Motors

2025

An open-source, high-performance field oriented control (FOC) framework for BLDC and PMSM motors. Built on a modular, abstract architecture, every core module is configurable at run-time, enabling iFOC to support multiple control modes and deployment across multiple platforms. This project serves as a fundamental platform for my follow-up works, including surgical robots, robot arms, etc.

[Code]

2024

Maglev: Magnetic Levitation System

2024

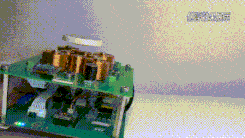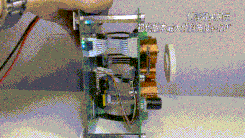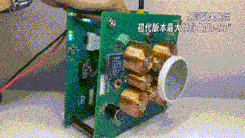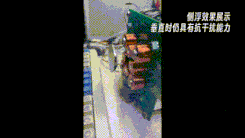
A magnetic levitation platform that combines cascaded current + position + 3D attitude PID loops to stabilize and control a levitated magnet disk. The system supports closed-loop height and orbital motion control, recovers from external disturbances, and maintains stable levitation with the base tilted by up to 135°-140°.

[Code] [Demo] [Report]